Interpretable Autonomous Driving VLA through Belief Distillation (IBD)
Ongoing project (Sep. 2026 – present): a driving VLA’s commentary is both an explanation and a control input. IBD keeps the commentary honest and moves the safety knowledge in privileged simulator labels into a camera-only belief token with a readable risk map.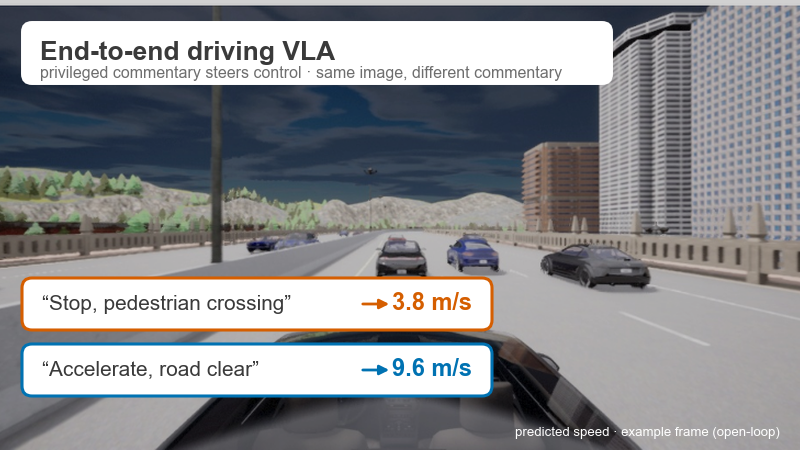
진행 중인 프로젝트(2026년 9월 – 현재): 주행 VLA의 해설은 설명이면서 제어 입력입니다. IBD는 해설을 정직하게 유지하고, 특권 시뮬레이터 라벨의 안전 지식을 사람이 읽을 수 있는 위험 지도를 가진 카메라 기반 신념 토큰으로 옮깁니다.
进行中的项目(2026年9月至今):驾驶 VLA 的解说既是解释也是控制输入。IBD 让解说保持如实,并把特权仿真标签中的安全知识转移到仅依赖相机、带可读风险地图的信念 token 中。