Sitemap사이트맵网站地图
A list of all the pages on this site. An XML version is also available.이 사이트의 전체 페이지 목록입니다. XML 버전도 있습니다.本站全部页面列表。另有 XML 版本。
Pages페이지页面
Projects프로젝트项目
Interpretable Autonomous Driving VLA through Belief Distillation (IBD)
Ongoing project (Sep. 2026 – present): a driving VLA’s commentary is both an explanation and a control input. IBD keeps the commentary honest and moves the safety knowledge in privileged simulator labels into a camera-only belief token with a readable risk map.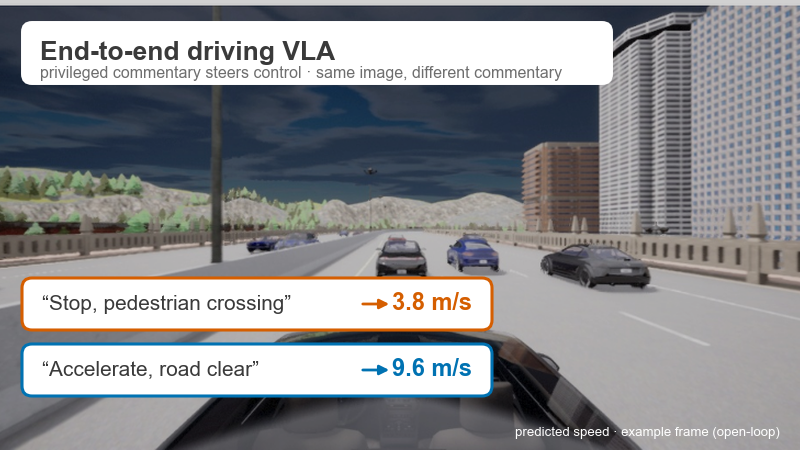
진행 중인 프로젝트(2026년 9월 – 현재): 주행 VLA의 해설은 설명이면서 제어 입력입니다. IBD는 해설을 정직하게 유지하고, 특권 시뮬레이터 라벨의 안전 지식을 사람이 읽을 수 있는 위험 지도를 가진 카메라 기반 신념 토큰으로 옮깁니다.
进行中的项目(2026年9月至今):驾驶 VLA 的解说既是解释也是控制输入。IBD 让解说保持如实,并把特权仿真标签中的安全知识转移到仅依赖相机、带可读风险地图的信念 token 中。
Route-Guided CBF-QP Repair: Safe Obstacle Bypass for VLA Robot Policies
LG Electronics Toronto AI Lab (Jan.–Aug. 2026): a post-hoc CBF-QP repair module that gives a VLA robot policy a recoverable route around obstacles. SafeLIBERO collision avoidance 64.7% → 69.1% (4-suite average vs. AEGIS). First-author RSS 2026 Workshop paper.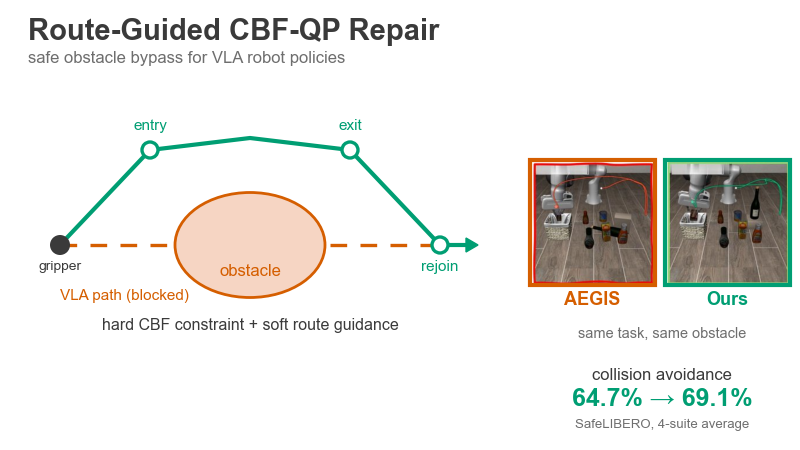
LG Electronics Toronto AI Lab (2026년 1월 – 8월): VLA 로봇 정책에 장애물을 돌아 복귀하는 경로를 주는 사후 CBF-QP 복구 모듈. SafeLIBERO 충돌 회피율 64.7% → 69.1% (4개 스위트 평균, AEGIS 대비). RSS 2026 Workshop 제1저자 논문.
LG Electronics Toronto AI Lab(2026年1月–8月):事后 CBF-QP 修复模块,为 VLA 机器人策略提供绕过障碍并能返回任务的路径。SafeLIBERO 避碰率 64.7% → 69.1%(4 个套件平均,对比 AEGIS)。RSS 2026 Workshop 第一作者论文。
LLM Agent Research Pipeline with Cross-Model Review
Personal project (Sep. 2026): a multi-agent research workflow on the open-source ARIS skill pack, plus my cross-model-family reviewer harness with provenance logging.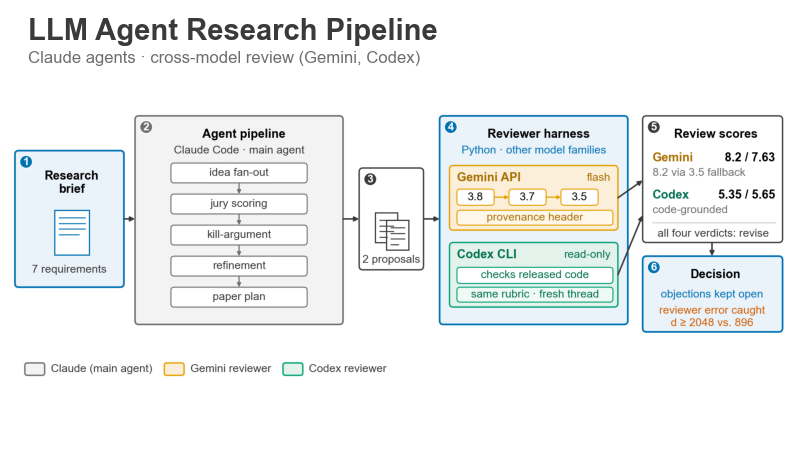
개인 프로젝트(2026년 9월): 오픈소스 ARIS 스킬 팩 기반 멀티 에이전트 연구 워크플로와, 직접 만든 출처 기록형 교차 모델 리뷰어 하네스.
个人项目(2026年9月):基于开源 ARIS 技能包的多智能体研究工作流,以及我搭建的带来源记录的跨模型族评审框架。
Submersivity: XR-Guided Underwater Debris Detection
Mann Lab, University of Toronto (Jan.–Jul. 2026): an RC submarine, a YOLOv8s debris detector, basin localization and an XR goggle HUD for cleanup swimmers. IEEE ICMA 2026; built jointly with the first two authors.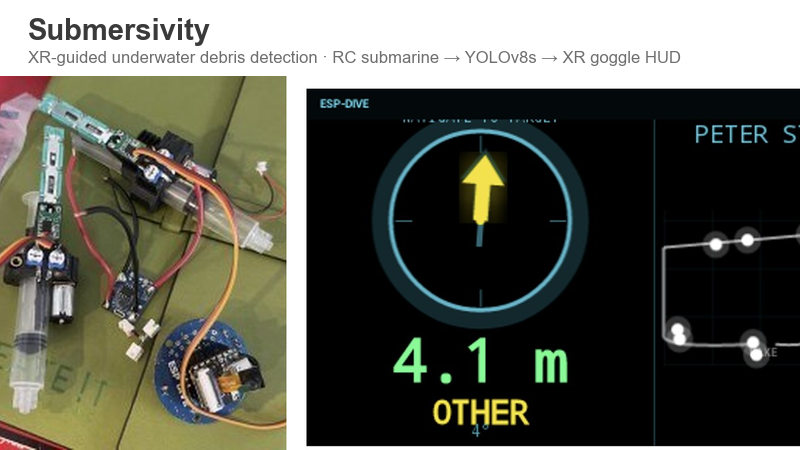
Mann Lab, University of Toronto (2026년 1월 – 7월): 수중 청소를 위한 RC 잠수정, YOLOv8s 쓰레기 탐지 모델, 수조 위치 추정, XR 고글 HUD. IEEE ICMA 2026 (제1·2저자와 공동 개발).
Mann Lab, University of Toronto(2026年1月–7月):面向水下清理的 RC 潜艇、YOLOv8s 垃圾检测器、水池定位与 XR 泳镜 HUD。IEEE ICMA 2026(与前两位作者共同完成)。
MetaForensic: Partial-Manipulation Deepfake Attacks (KIISE Excellence Award)
KIISE Deepfake Generation & Detection Competition, red-team track (Jun. 2025): a team partial-manipulation deepfake pipeline that won the Excellence Award (Jul. 2025).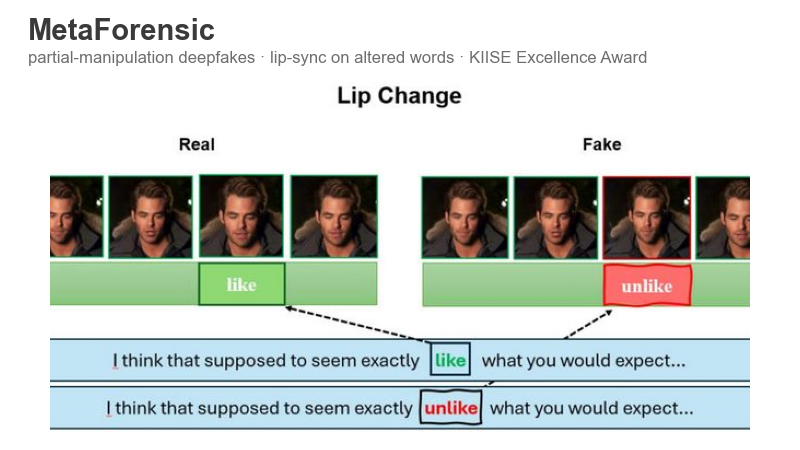
KIISE 딥페이크 생성·탐지 경진대회 레드팀 트랙(2025년 6월): 팀으로 만든 부분 조작 딥페이크 파이프라인으로 우수상 수상(2025년 7월).
KIISE 深度伪造生成与检测竞赛红队赛道(2025年6月):团队构建的局部篡改深度伪造流程,获优秀奖(2025年7月)。
Undergraduate Projects
Four projects from my B.S. in Industrial Engineering at Inha University (2017–2023): an autonomous RC car, hydrogen-station site evaluation, a Korean-food classifier app, and a 3D figure generation platform.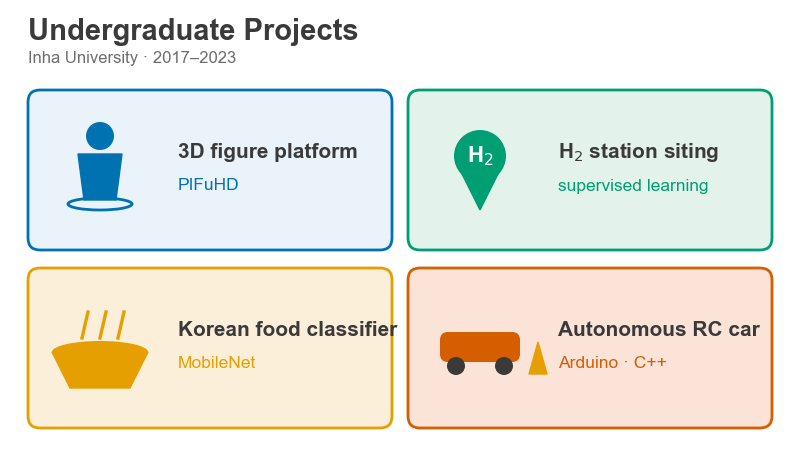
Inha University 산업공학 학사 과정(2017–2023)의 네 프로젝트: 자율주행 RC카, 수소충전소 입지 평가, 한식 분류 앱, 3D 피규어 생성 플랫폼.
我在 Inha University 工业工程本科期间(2017–2023)的四个项目:自动驾驶 RC 小车、加氢站选址评估、韩餐分类应用和 3D 手办生成平台。
Publications논문论文
Weighted Contrastive Learning for Robust Audio-Visual Deepfake Detection
Under review심사 중审稿中
HashFormer: weighted contrastive alignment in a binary hash space for audio-visual deepfake detection, designed for missing-modality robustness. Under review.
HashFormer: weighted contrastive alignment in a binary hash space for audio-visual deepfake detection, designed for missing-modality robustness. Under review.
HashFormer: weighted contrastive alignment in a binary hash space for audio-visual deepfake detection, designed for missing-modality robustness. Under review.
Where Are the Artifacts? Residual-Guided Representation Learning for Deepfake Detection and Localization
Under review심사 중审稿中
Residual-guided representation learning for deepfake detection and localization. Under review.
Residual-guided representation learning for deepfake detection and localization. Under review.
Residual-guided representation learning for deepfake detection and localization. Under review.
X3A: Efficient Multimodal Deepfake Detection with Score-Level Fusion
ACM/SIGAPP Symposium on Applied Computing (SAC) 2025
X3A: video-level audio-visual deepfake detection by score-level fusion of X3D (raw video) and AASIST (raw audio); ACM SAC 2025, equal-contribution first author.
X3A: video-level audio-visual deepfake detection by score-level fusion of X3D (raw video) and AASIST (raw audio); ACM SAC 2025, equal-contribution first author.
X3A: video-level audio-visual deepfake detection by score-level fusion of X3D (raw video) and AASIST (raw audio); ACM SAC 2025, equal-contribution first author.
Beyond Masking: Landmark-based Representation Learning and Knowledge-Distillation for Audio-Visual Deepfake Detection
ACM International Conference on Information and Knowledge Management (CIKM) 2025, Short Paper
Landmark-based distillation and audio-visual temporal alignment for deepfake detection that generalizes to real-world web deepfakes (CIKM 2025 short paper, first author).
Landmark-based distillation and audio-visual temporal alignment for deepfake detection that generalizes to real-world web deepfakes (CIKM 2025 short paper, first author).
Landmark-based distillation and audio-visual temporal alignment for deepfake detection that generalizes to real-world web deepfakes (CIKM 2025 short paper, first author).
ICR-Net: Robust Deepfake Detection under Temporal Corruption
Pacific-Asia Conference on Knowledge Discovery and Data Mining (PAKDD) 2026
DF-TCB benchmark and ICR-Net: deepfake detection that stays accurate under live-streaming temporal corruptions (PAKDD 2026, first author).
DF-TCB benchmark and ICR-Net: deepfake detection that stays accurate under live-streaming temporal corruptions (PAKDD 2026, first author).
DF-TCB benchmark and ICR-Net: deepfake detection that stays accurate under live-streaming temporal corruptions (PAKDD 2026, first author).
State-of-Flight: Wearable EEG and Motion Context During Flying or Floating
IEEE International Symposium on Computer-Based Medical Systems (CBMS) 2026
An in-cabin wearable EEG + IMU protocol and analysis pipeline for a hypothesized State-of-Flight/Float transition (IEEE CBMS 2026, co-author).
An in-cabin wearable EEG + IMU protocol and analysis pipeline for a hypothesized State-of-Flight/Float transition (IEEE CBMS 2026, co-author).
An in-cabin wearable EEG + IMU protocol and analysis pipeline for a hypothesized State-of-Flight/Float transition (IEEE CBMS 2026, co-author).
Submersivity: XR-Guided Garbage Detection with an RC Submarine for Peter Street Basin Cleanup
IEEE International Conference on Mechatronics and Automation (ICMA) 2026
XR-guided underwater garbage detection with an RC submarine, a YOLOv8s detector, basin localization and a swim-goggle HUD (IEEE ICMA 2026; built jointly with the first two authors).
XR-guided underwater garbage detection with an RC submarine, a YOLOv8s detector, basin localization and a swim-goggle HUD (IEEE ICMA 2026; built jointly with the first two authors).
XR-guided underwater garbage detection with an RC submarine, a YOLOv8s detector, basin localization and a swim-goggle HUD (IEEE ICMA 2026; built jointly with the first two authors).
Route-Guided CBF-QP Repair for Safe Vision-Language-Action Models
RSS 2026 Workshop on Trustworthy Embodied Foundation Models
Route-Guided CBF-QP Repair: a post-hoc safety repair module that gives VLA robot policies a recoverable route around obstacles (RSS 2026 Workshop, first author).
Route-Guided CBF-QP Repair: a post-hoc safety repair module that gives VLA robot policies a recoverable route around obstacles (RSS 2026 Workshop, first author).
Route-Guided CBF-QP Repair: a post-hoc safety repair module that gives VLA robot policies a recoverable route around obstacles (RSS 2026 Workshop, first author).
Interpretable Autonomous Driving VLA through Belief Distillation (IBD)
Ongoing project진행 중인 프로젝트进行中的项目
Ongoing project: honest commentary for a driving VLA, with the safety knowledge in privileged simulator labels moved into a camera-only belief token and risk map.
Ongoing project: honest commentary for a driving VLA, with the safety knowledge in privileged simulator labels moved into a camera-only belief token and risk map.
Ongoing project: honest commentary for a driving VLA, with the safety knowledge in privileged simulator labels moved into a camera-only belief token and risk map.